

The problem
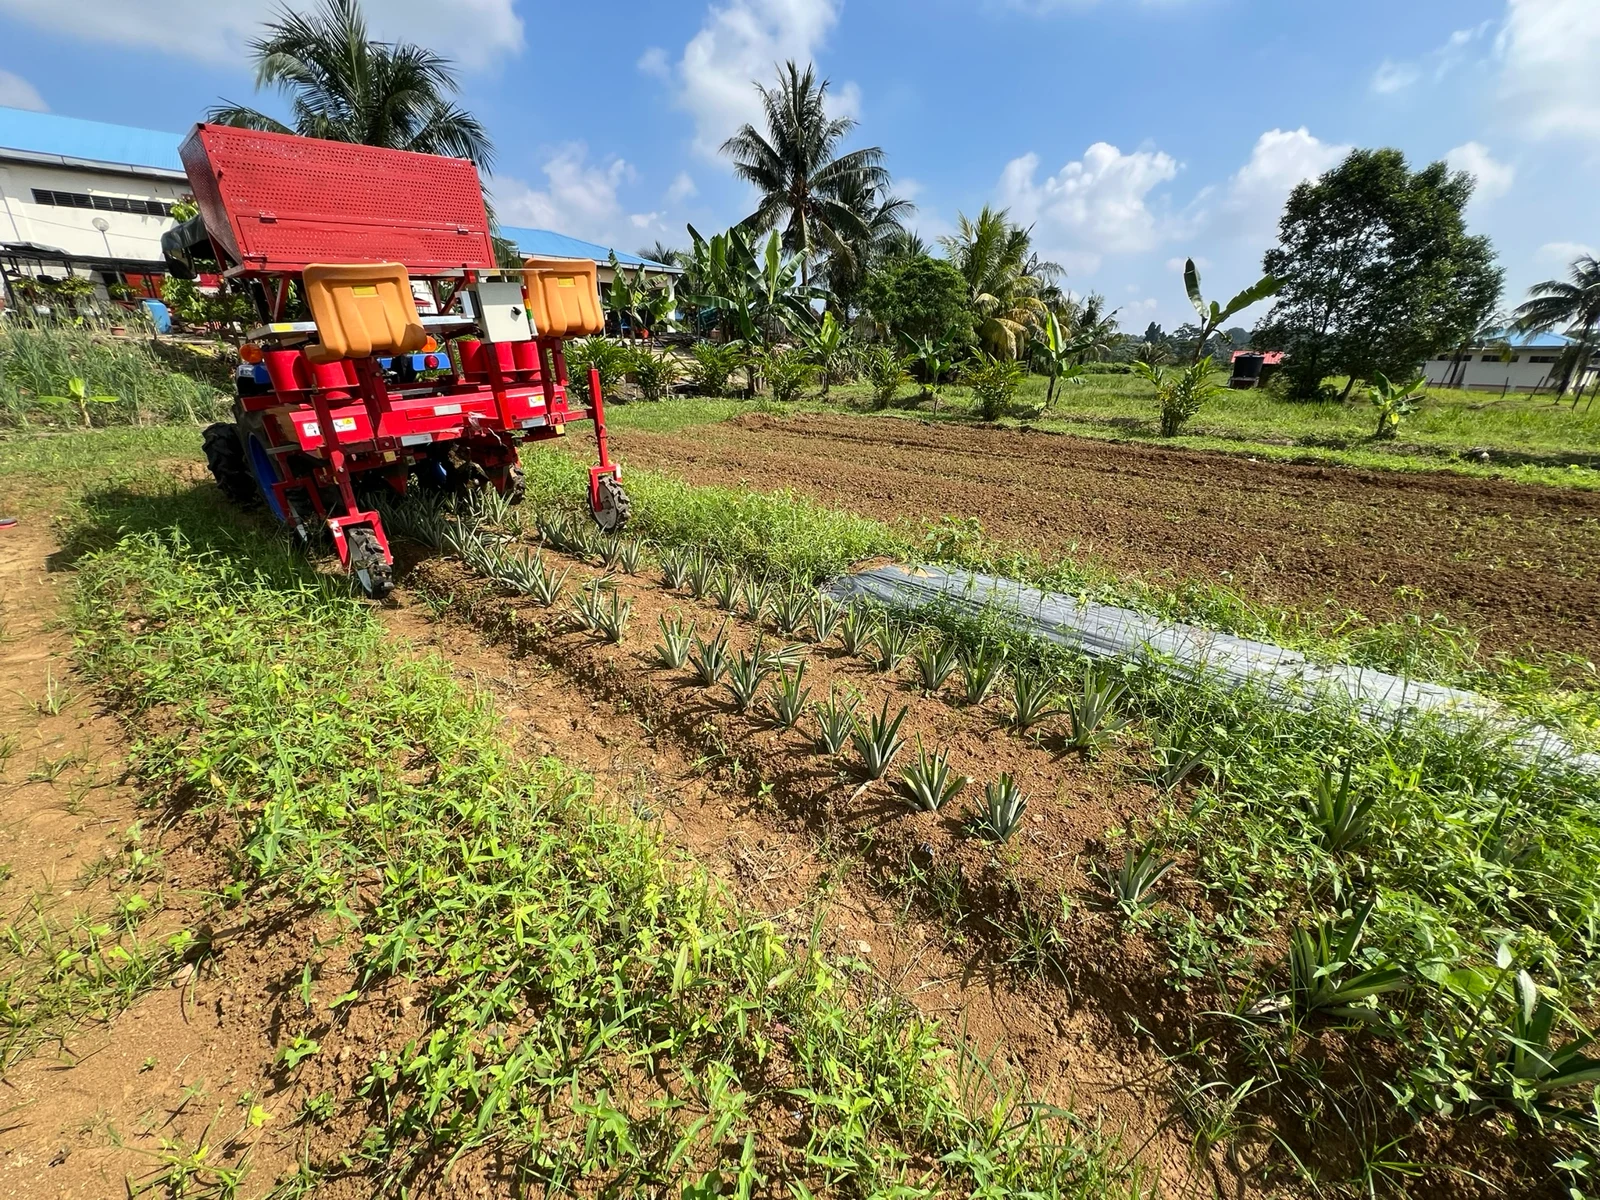
Mechanised planting needs immediate checks for tilted, incorrectly placed or missing pineapple suckers. Harvesting also needs consistent fruit sizing and grading under real field conditions.
Our approach
We developed planting-inspection and harvest-grading systems on NVIDIA Jetson hardware. Planting models classify sucker placement and trigger tower-light alerts. Harvesting models use MARDI calibration data to translate visual measurements into size and weight-based grades. Both systems were validated on MARDI plots.
The engineering challenge
Processing moving footage under changing sunlight, clutter and partial visibility on compact edge hardware. Tracking avoids duplicate counts, while calibrated image measurements provide useful physical estimates.
What the work supports
Immediate planting-quality feedback, field-session records and vision-assisted fruit grading within MARDI’s agricultural mechanisation programme.